PHAM DUC DUY.
Closing the gap between
autonomous navigation research and deployed hardware.
Shipped ROS 2 robots in hospitals, restaurants, and factories. At VinRobotics, I build factory integrations and VLA manipulation systems; at HaiBotLab, I lead Embodied AI research. Co-authored a MethodsX Q2 paper on distributional RL path planning.
What I actually do.
Most robotics demos work in ideal conditions. My job is to make them work when they don't — when the LiDAR scan is partial, the floor is reflective, the network drops packets, and the operator expects the robot to keep moving. I tune DDS QoS profiles and ROS 2 executor strategies for real-time performance, configure Cartographer SLAM for constrained hardware, and debug Nav2 failure modes that never appear in simulation.
At ByteHome Robotics, I led the full cycle from prototype to commercialized product — hardware integration, software stack, and the rarely-mentioned last mile: writing operator handbooks for independent fleet operation without ongoing engineering support.
At HaiBotLab I'm focused on the harder problem — moving beyond scripted navigation toward robots that understand unstructured 3D environments. We work with depth images, point cloud pipelines, and Micro-ROS on ESP32 running RTOS for low-latency sensor communication.
Core Stack
Where I've built things.
- Designed and implemented a robot license management system — cryptographic activation, feature gating, and telemetry reporting — for fleet deployments.
- Integrated software for factory automation projects at VF, supporting assembly-line QC workflows and reducing manual inspection steps.
- Working on VLA for robotic arms on rich-contact tasks, including pick-and-insert.
- At a small robotics startup, led a 5-engineer team building differential-drive service robots for hospitality and healthcare — full ROS 2 stack: sensor drivers, Cartographer SLAM, Nav2 planners/controllers, multilingual voice interaction.
- Took the product from internal prototype to commercial deployment, including hardware integration, safety testing, and regulatory documentation.
- Wrote operator handbooks for independent fleet operation without ongoing engineering support.
- Direct lab research on Embodied AI: representation learning from egocentric observations, manipulation policy training in MuJoCo, sim-to-real transfer of perception modules.
- Built point cloud and depth image processing pipelines (Intel D435, Visionary-T) for 3D object detection in unstructured environments.
- Developed Micro-ROS firmware on ESP32 with FreeRTOS — sub-5ms sensor publish latency enabling tight control loops between embedded hardware and the ROS 2 compute graph.
- 2nd Prize, University Scientific Research 2026 — Satellite image map recognition via image processing and deep learning.
- 2nd Prize, University Informatics Olympiad 2025.
- 3rd Prize, University Scientific Research 2025 — Object detection from depth sensor data. Consolation Prize 2024 — Pick-and-place trajectory optimization on a TOSHIBA DC650B die-casting cell.
- 3rd Prize, University Student Mathematics Competition 2023 (Linear Algebra).
Projects I've shipped.
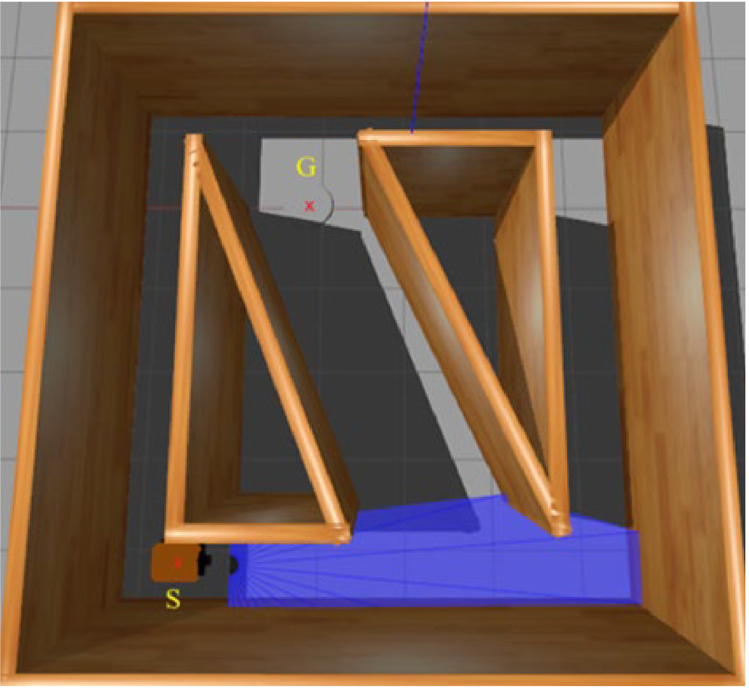
Published work & recognition.
Let's work on something real.
Looking for roles where the robots actually ship — not just simulate. Particularly interested in teams working on autonomous mobile robots, Embodied AI, or edge-compute robotics stacks where the distance between a ROS 2 node and a physical actuator is short.
Research collaborations welcome: sim-to-real transfer, distributional RL, or perception for navigation. If you're training operators on ROS 2 and need someone who's done it before — that too.
Based in Hanoi, Vietnam.
Open to international roles — remote-first or relocation.